CrowdNav
Website | Paper | Video
This repository contains the codes for our ICRA 2019 paper. For more details, please refer to the paper
Crowd-Robot Interaction: Crowd-aware Robot Navigation with Attention-based Deep Reinforcement Learning.
Please find our more recent work in the following links
Abstract
Mobility in an effective and socially-compliant manner is an essential yet challenging task for robots operating in crowded spaces.
Recent works have shown the power of deep reinforcement learning techniques to learn socially cooperative policies.
However, their cooperation ability deteriorates as the crowd grows since they typically relax the problem as a one-way Human-Robot interaction problem.
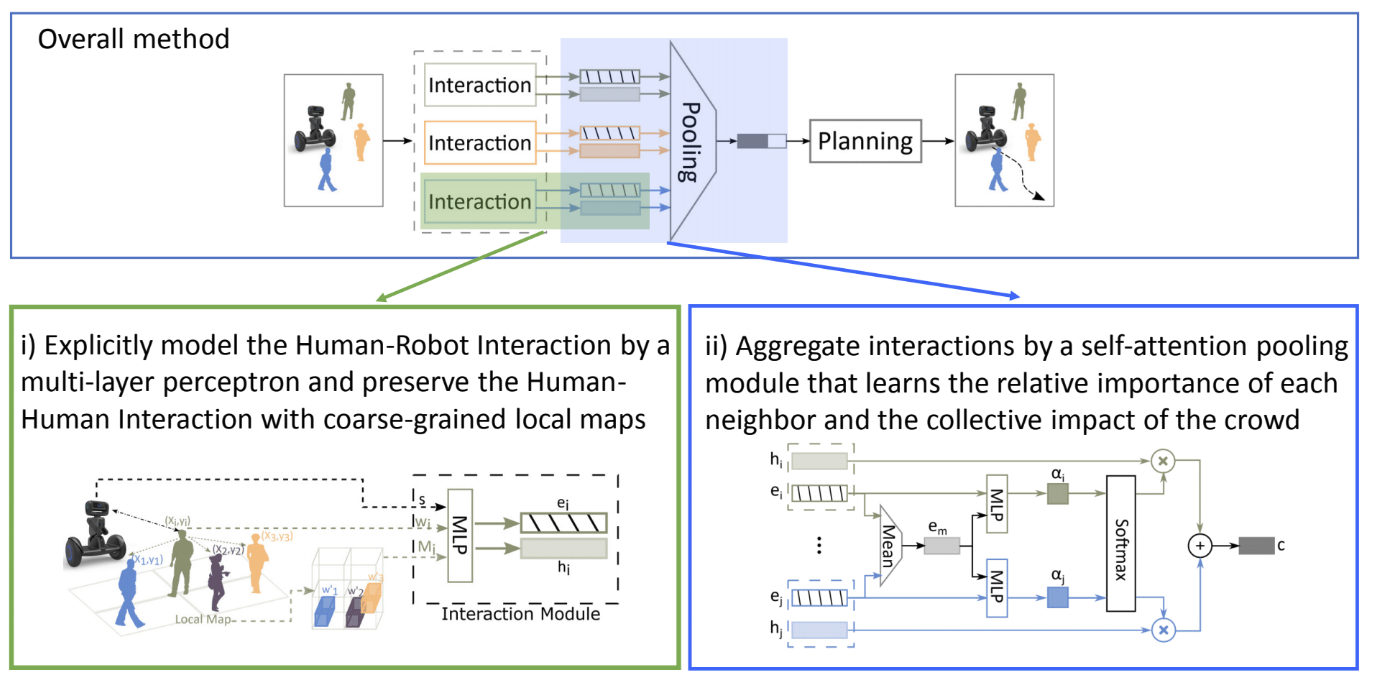
In this work, we want to go beyond first-order Human-Robot interaction and more explicitly model Crowd-Robot Interaction (CRI).
We propose to (i) rethink pairwise interactions with a self-attention mechanism, and
(ii) jointly model Human-Robot as well as Human-Human interactions in the deep reinforcement learning framework.
Our model captures the Human-Human interactions occurring in dense crowds that indirectly affects the robot’s anticipation capability.
Our proposed attentive pooling mechanism learns the collective importance of neighboring humans with respect to their future states.
Various experiments demonstrate that our model can anticipate human dynamics and navigate in crowds with time efficiency,
outperforming state-of-the-art methods.
Method Overview
Setup
- Install Python-RVO2 library
- Install crowd_sim and crowd_nav into pip
pip install -e .
Getting Started
This repository is organized in two parts: gym_crowd/ folder contains the simulation environment and
crowd_nav/ folder contains codes for training and testing the policies. Details of the simulation framework can be found
here. Below are the instructions for training and testing policies, and they should be executed
inside the crowd_nav/ folder.
- Train a policy.
python train.py --policy sarl
- Test policies with 500 test cases.
python test.py --policy orca --phase test
python test.py --policy sarl --model_dir data/output --phase test
- Run policy for one episode and visualize the result.
python test.py --policy orca --phase test --visualize --test_case 0
python test.py --policy sarl --model_dir data/output --phase test --visualize --test_case 0
- Visualize a test case.
python test.py --policy sarl --model_dir data/output --phase test --visualize --test_case 0
- Plot training curve.
python utils/plot.py data/output/output.log
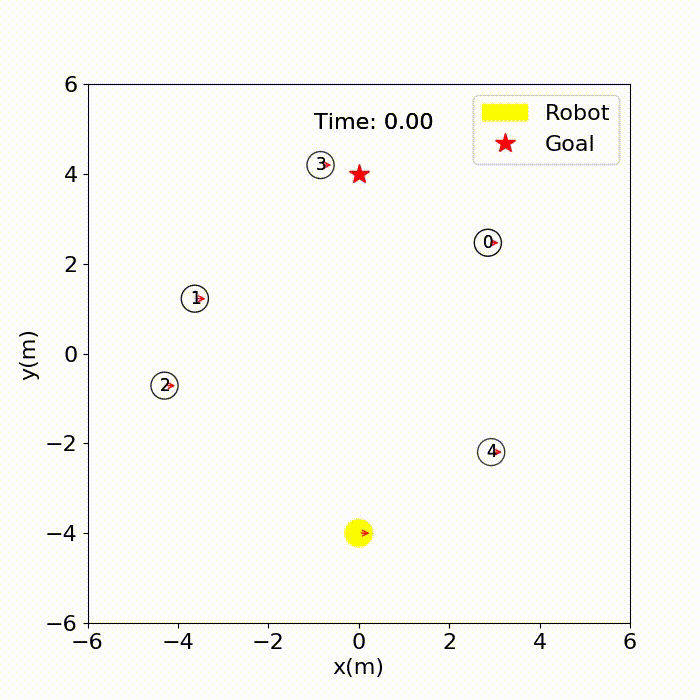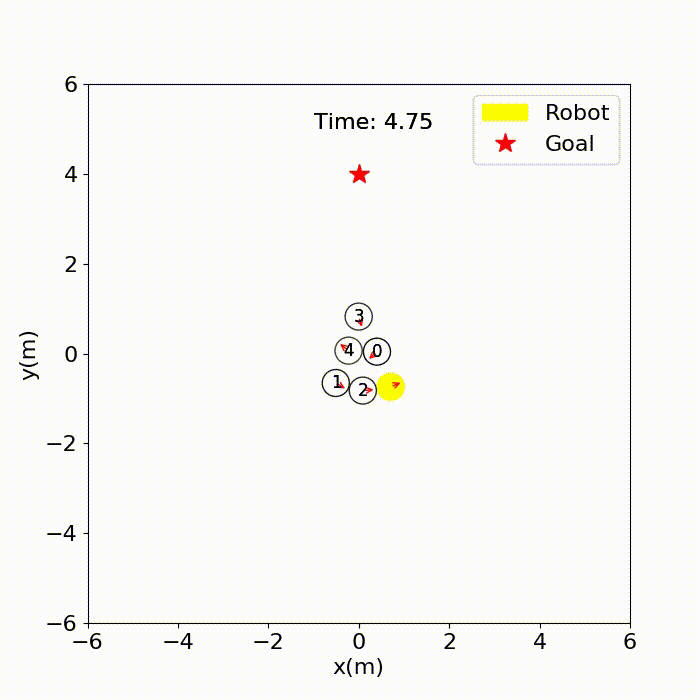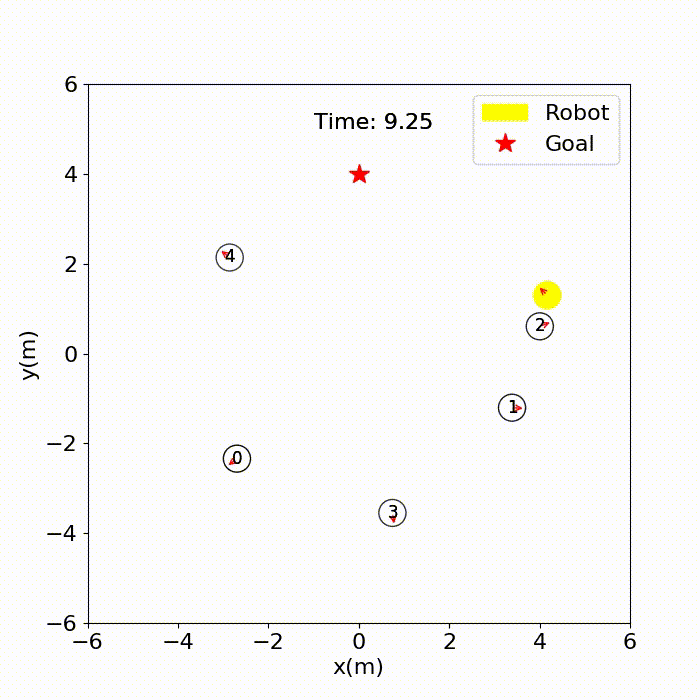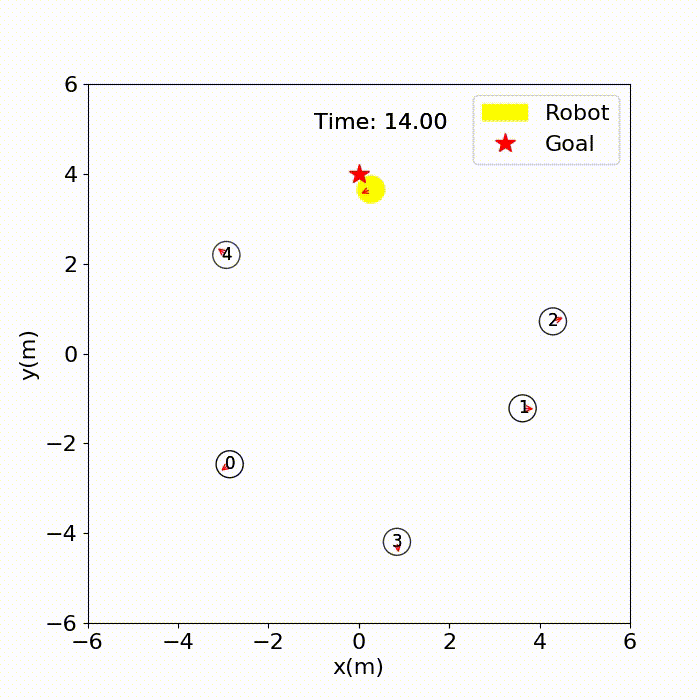
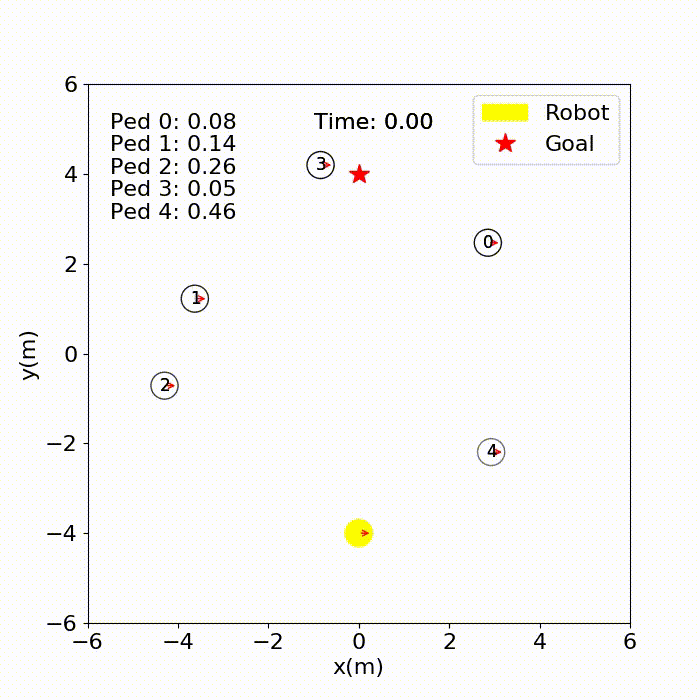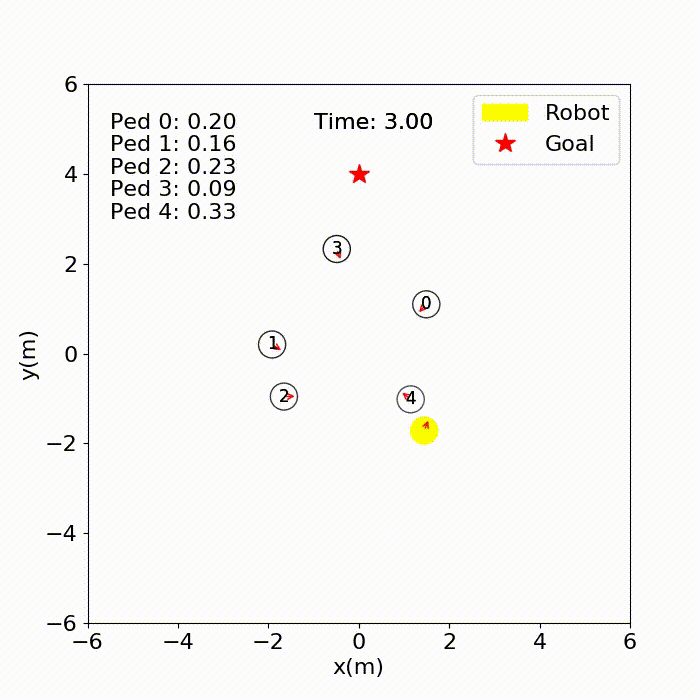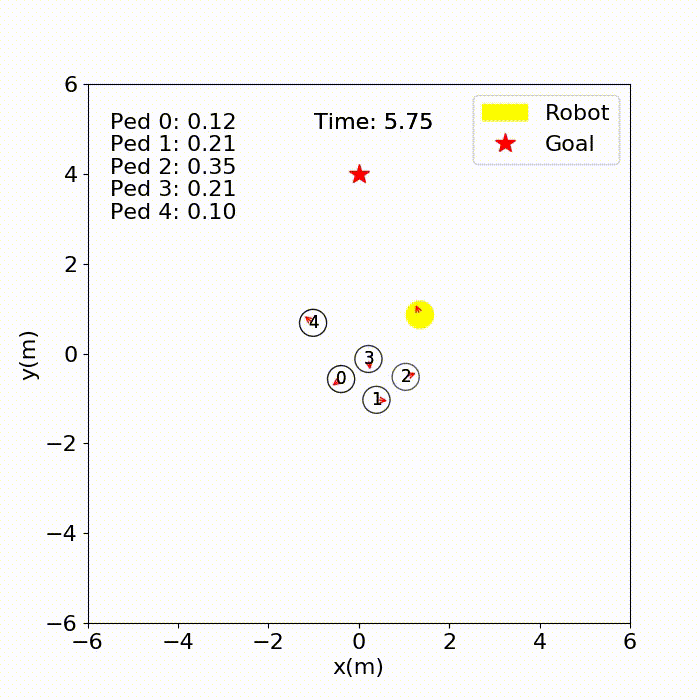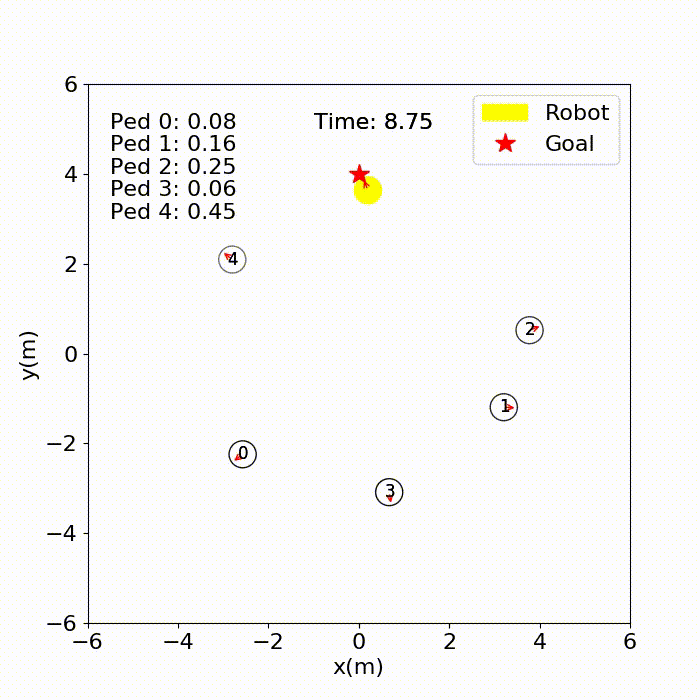
Simulation Videos
| CADRL |
LSTM-RL |
 |
 |
| SARL |
OM-SARL |
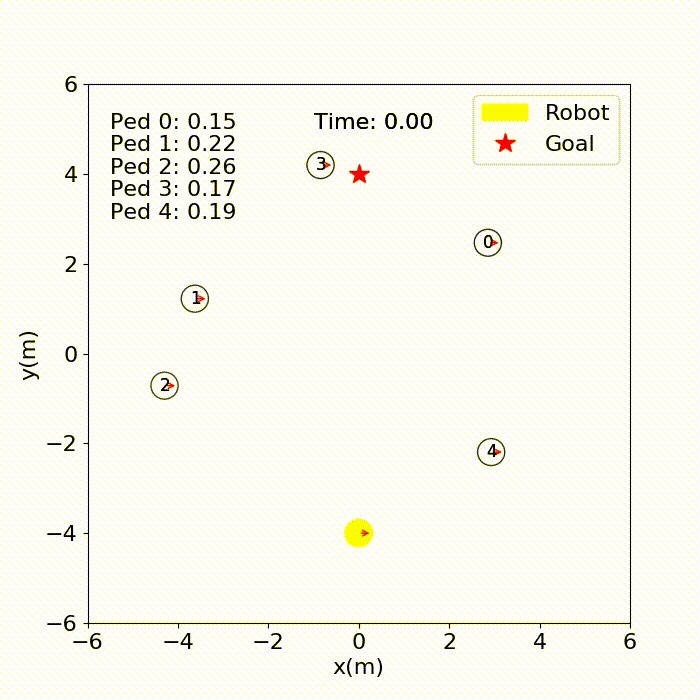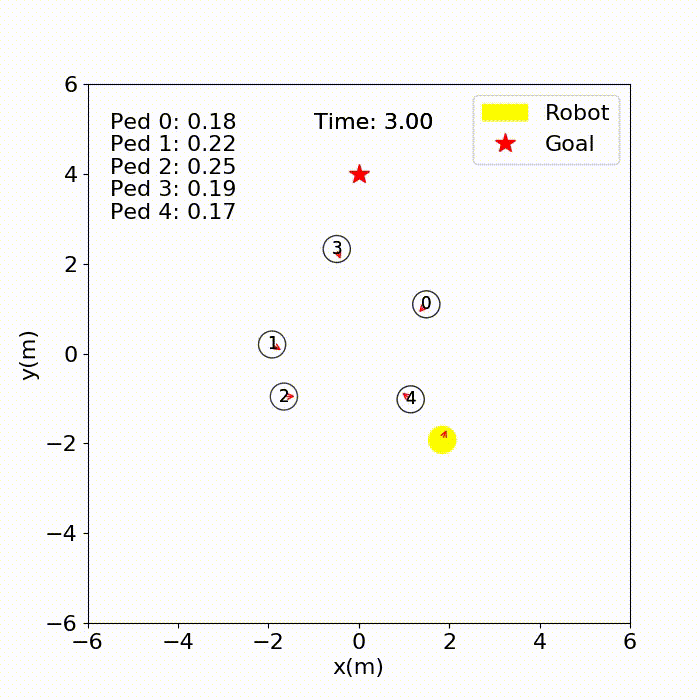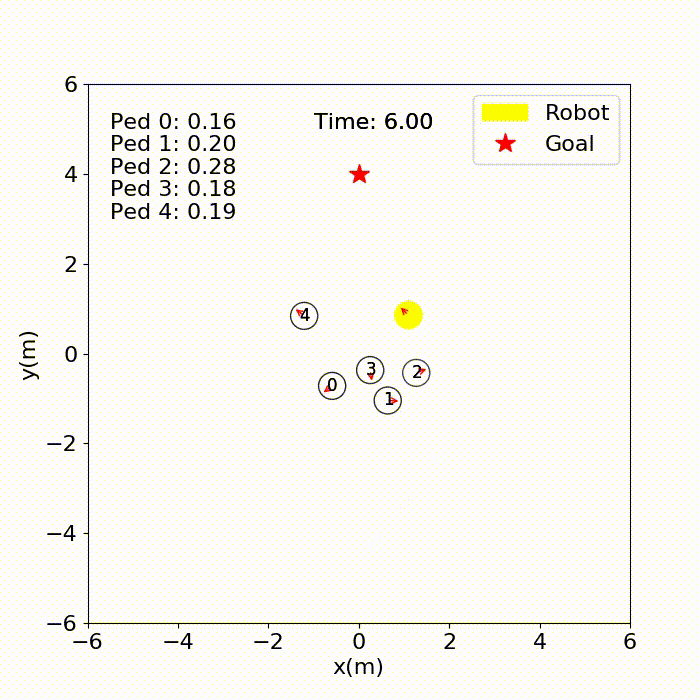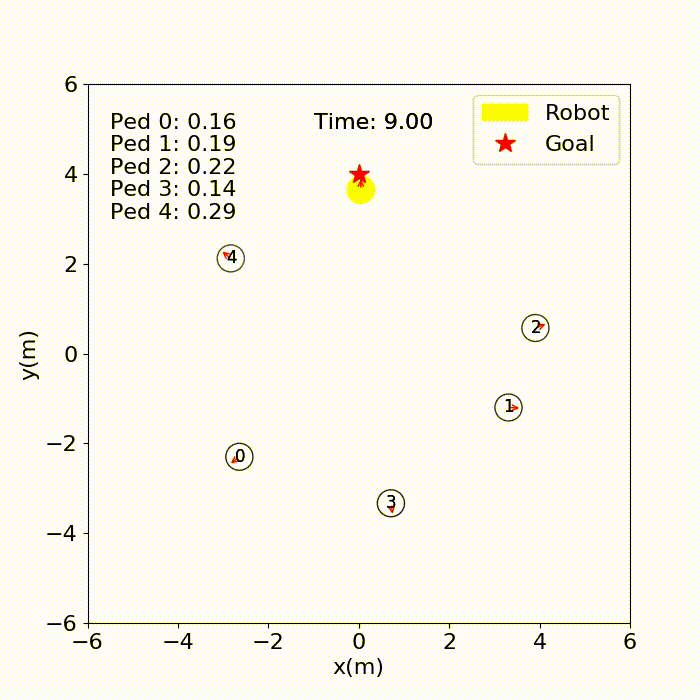 |
 |
Learning Curve
Learning curve comparison between different methods in an invisible setting.

Citation
If you find the codes or paper useful for your research, please cite our paper:
@inproceedings{chen2019crowd,
  title={Crowd-robot interaction: Crowd-aware robot navigation with attention-based deep reinforcement learning},
  author={Chen, Changan and Liu, Yuejiang and Kreiss, Sven and Alahi, Alexandre},
  booktitle={2019 International Conference on Robotics and Automation (ICRA)},
  pages={6015--6022},
  year={2019},
  organization={IEEE}
}


评论