Introduction
Motion planning plans the state sequence of the robot without conflict between the start and goal.
Motion planning mainly includes Path planning and Trajectory planning.
Path Planning: It’s based on path constraints (such as obstacles), planning the optimal path sequence for the robot to travel without conflict between the start and goal.Trajectory planning: It plans the motion state to approach the global path based on kinematics, dynamics constraints and path sequence.
This repository provides the implement of common Motion planning algorithm, welcome your star & fork & PR.
This repository provides the implementation of common Motion Planning algorithms. The theory analysis can be found at motion-planning. Furthermore, we provide ROS C++ and Python version.
Quick Start
The file structure is shown below
├─gif
├─examples
│   ├─simulation_global.mlx
│   ├─simulation_local.mlx
│   ├─simulation_total.mlx
├─global_planner
│   ├─graph_search
│   ├─sample_search
│   └─evolutionary_search
├─local_planner
└─utils
The global planning algorithm implementation is in the folder global_planner with graph_search, sample_search and evolutionary search; The local planning algorithm implementation is in the folder local_planner.
To start simulation, open ./simulation_global.mlx or ./simulation_local.mlx and select the algorithm, for example
clear all;
clc;

% load environment
load("gridmap_20x20_scene1.mat");
map_size = size(grid_map);
G = 1;

% start and goal
start = [3, 2];
goal = [18, 29];

% planner
planner_name = "rrt";

planner = str2func(planner_name);
[path, flag, cost, expand] = planner(grid_map, start, goal);

% visualization
clf;
hold on

% plot grid map
plot_grid(grid_map);
% plot expand zone
plot_expand(expand, map_size, G, planner_name);
% plot path
plot_path(path, G);
% plot start and goal
plot_square(start, map_size, G, "#f00");
plot_square(goal, map_size, G, "#15c");
% title
title([planner_name, "cost:" + num2str(cost)]);

hold off
Version
Global Planner
| Planner |
Version |
Animation |
| GBFS |
 |
 |
| Dijkstra |
|
 |
| A* |
|
 |
| JPS |
|
 |
| Theta* |
|
 |
| Lazy Theta* |
|
 |
| D* |
|
 |
| LPA* |
 |
 |
| D* Lite |
|
|
| Voronoi |
|
 |
| RRT |
|
 |
| RRT* |
|
 |
| Informed RRT |
|
 |
| RRT-Connect |
|
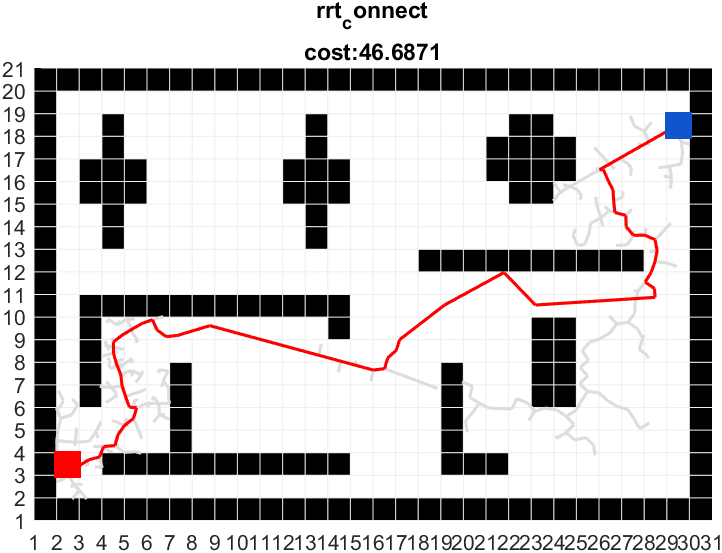 |
Local Planner
| Planner |
Version |
Animation |
| PID |
|
 |
| LQR |
|
 |
| MPC |
|
 |
| APF |
|
 |
| DWA |
|
 |
| RPP |
|
 |
| TEB |
|
|
| MPC |
|
|
| Lattice |
|
|
Intelligent Algorithm
| Planner |
Version |
Animation |
| ACO |
|
 |
| GA |
|
|
| PSO |
|
|
| ABC |
|
|
Curve Generation
| Planner |
Version |
Animation |
| Polynomia |
|
 |
| Bezier |
|
 |
| Cubic Spline |
|
 |
| BSpline |
|
 |
| Dubins |
|
 |
| Reeds-Shepp |
|
 |
Papers
Search-based Planning
- A*: A Formal Basis for the heuristic Determination of Minimum Cost Paths
- JPS: Online Graph Pruning for Pathfinding On Grid Maps
- Lifelong Planning A*: Lifelong Planning A*
- D*: Optimal and Efficient Path Planning for Partially-Known Environments
- D* Lite: D* Lite
- Theta*: Theta*: Any-Angle Path Planning on Grids
- Lazy Theta*: Lazy Theta*: Any-Angle Path Planning and Path Length Analysis in 3D
Sample-based Planning
- RRT: Rapidly-Exploring Random Trees: A New Tool for Path Planning
- RRT-Connect: RRT-Connect: An Efficient Approach to Single-Query Path Planning
- RRT*: Sampling-based algorithms for optimal motion planning
- Informed RRT*: Optimal Sampling-based Path Planning Focused via Direct Sampling of an Admissible Ellipsoidal heuristic
Evolutionary-based Planning
- ACO: Ant Colony Optimization: A New Meta-Heuristic
Local Planning
- DWA: The Dynamic Window Approach to Collision Avoidance
- APF: Real-time obstacle avoidance for manipulators and mobile robots
- RPP: Regulated Pure Pursuit for Robot Path Tracking
Curve Generation
- Dubins: On curves of minimal length with a constraint on average curvature, and with prescribed initial and terminal positions and tangents


评论