DiffBot

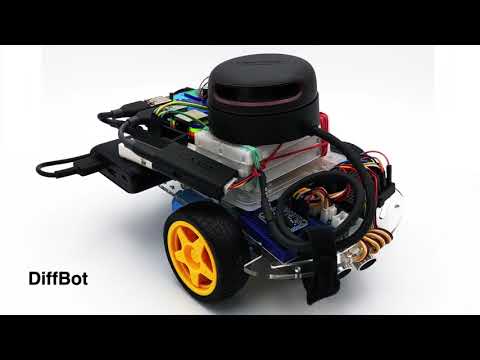
DiffBot is an autonomous differential drive robot with two wheels. Its main processing unit is a Raspberry Pi 4 B running Ubuntu Mate 20.04 and the ROS 1 (ROS Noetic) middleware. This respository contains ROS driver packages, ROS Control Hardware Interface for the real robot and configurations for simulating DiffBot. The formatted documentation can be found at: https://ros-mobile-robots.com.
| DiffBot |
Lidar SLAMTEC RPLidar A2 |
 |
 |
If you are looking for a 3D printable modular base, see the remo_description repository. You can use it directly with the software of this diffbot repository.
| Remo |
Gazebo Simulation |
RViz |
 |
 |
 |
It provides mounts for different camera modules, such as Raspi Cam v2, OAK-1, OAK-D and you can even design your own if you like. There is also support for different single board computers (Raspberry Pi and Nvidia Jetson Nano) through two changable decks. You are agin free to create your own.
Demonstration
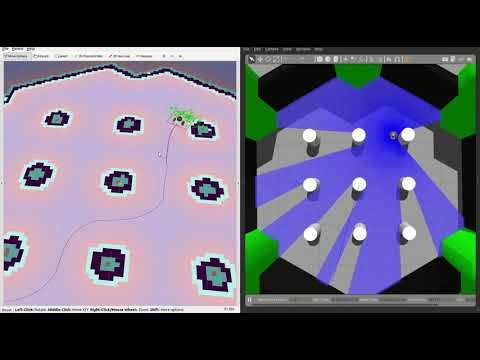
SLAM and Navigation
| Real robot |
Gazebo Simulation |
 |
  |
:package: Package Overview
Installation
The packages are written for and tested with ROS 1 Noetic on Ubuntu 20.04 Focal Fossa.
For the real robot Ubuntu Mate 20.04 for arm64 is installed on the Raspberry Pi 4 B with 4GB. The communication between the mobile robot and the work pc is done by configuring the ROS Network, see also the documentation.
Development Container
The quickest way to a working setup on a development PC is the dev container in .devcontainer/noetic: a Docker image with ROS Noetic, Gazebo 11 and everything the DiffBot packages need. It works on Linux and on Windows with WSL 2, and CI builds the same image.
The full guide is on the documentation site: Use the Dev Container (setup on Linux and Windows, usage, updating, troubleshooting) and How the Dev Container Works.
-
VS Code: install the Dev Containers extension, open your clone of this repository and choose Reopen in Container.
-
Command line: with the Dev Container CLI:
devcontainer up --workspace-folder . --config .devcontainer/noetic/devcontainer.json
devcontainer exec --workspace-folder . --config .devcontainer/noetic/devcontainer.json bash
Creating the container clones rplidar_ros and remo_description, installs missing dependencies with rosdep and builds the workspace in ~/catkin_ws. Your clone of this repository is mounted at ~/catkin_ws/src/diffbot, so edits on the host show up in the container. The container uses the host network to reach the robot.
RViz and Gazebo open on the host’s display. On Windows, WSLg needs no setup. On a native Linux desktop (X11 or Wayland with Xwayland), install xauth on the host (sudo apt install xauth): before the container starts, host-x11.sh copies your display’s X11 cookie to .devcontainer/noetic/.x11/ (ignored by Git), where the container reads it. So xhost + isn’t needed.
Plain Docker works too. The image’s user has UID 1000; with another UID, use the dev container, which adapts it.
docker build -f .devcontainer/noetic/Dockerfile -t diffbot:noetic .
bash .devcontainer/noetic/host-x11.sh
docker run -it --rm --net=host -v /tmp/.X11-unix:/tmp/.X11-unix -e DISPLAY \
  -e XAUTHORITY=/home/ros/catkin_ws/src/diffbot/.devcontainer/noetic/.x11/xauth \
  -v "$PWD":/home/ros/catkin_ws/src/diffbot diffbot:noetic \
  bash -c "bash src/diffbot/.devcontainer/noetic/setup.sh && bash"
To set up a workspace without Docker, for example on the robot’s Raspberry Pi, follow the steps below.
Dependencies
The required Ubuntu packages are listed in software package sections found in the documentation. Other ROS catkin packages such as rplidar_ros need to be cloned into the catkin workspace.
For an automated and simplified dependency installation process install the vcstool, which is used in the next steps.
sudo apt install python3-vcstool
:hammer: How to Build
To build the packages in this repository including the Remo robot follow these steps:
-
cd into an existing ROS Noetic catkin workspace or create a new one:
mkdir -p catkin_ws/src
-
Clone this repository in the src folder of your ROS Noetic catkin workspace:
cd catkin_ws/src
git clone https://github.com/fjp/diffbot.git
-
Execute the vcs import command from the root of the catkin workspace and pipe in the diffbot_dev.repos or remo_robot.repos YAML file, depending on where you execute the command, either the development PC or the SBC of Remo to clone the listed dependencies. Run the following command only on your development machine:
vcs import < src/diffbot/diffbot_dev.repos
Run the next command on Remo robot’s SBC:
vcs import < src/diffbot/remo_robot.repos
-
Install the requried binary dependencies of all packages in the catkin workspace using the following rosdep command:
rosdep install --from-paths src --ignore-src -r -y
-
After installing the required dependencies build the catkin workspace, either with catkin_make:
catkin_ws$ catkin_make
or using catkin-tools:
catkin_ws$ catkin build
-
Finally, source the newly built packages with the devel/setup.* script, depending on your used shell:
For bash use:
catkin_ws$ source devel/setup.bash
For zsh use:
catkin_ws$ source devel/setup.zsh
Usage
The following sections describe how to run the robot simulation and how to make use of the real hardware using the available package launch files.
Gazebo Simulation with ROS Control
Control the robot inside Gazebo and view what it sees in RViz using the following launch file:
roslaunch diffbot_control diffbot.launch
This will launch the default diffbot world db_world.world.
To run the turtlebot3_world
make sure to download it to your ~/.gazebo/models/ folder, because the turtlebot3_world.world file references the turtlebot3_world model.
After that you can run it with the following command:
roslaunch diffbot_control diffbot.launch world_name:='$(find diffbot_gazebo)/worlds/turtlebot3_world.world'
db_world.world |
turtlebot3_world.world |
 |
 |
Navigation
To navigate the robot in the Gazebo simulator in db_world.world run the command:
roslaunch diffbot_navigation diffbot.launch
This uses a previously mapped map of db_world.world (found in diffbot_navigation/maps) that is served by
the map_server. With this you can use the 2D Nav Goal in RViz directly to let the robot drive autonomously in the db_world.world.

To run the turtlebot3_world.world (or your own stored world and map) use the same diffbot_navigation/launch/diffbot.launch file but change
the world_name and map_file arguments to your desired world and map yaml files:
roslaunch diffbot_navigation diffbot.launch world_name:='$(find diffbot_gazebo)/worlds/turtlebot3_world.world' map_file:='$(find diffbot_navigation)/maps/map.yaml'

SLAM
To map a new simulated environment using slam gmapping, first run
roslaunch diffbot_gazebo diffbot.launch world_name:='$(find diffbot_gazebo)/worlds/turtlebot3_world.world'
and in a second terminal execute
roslaunch diffbot_slam diffbot_slam.launch slam_method:=gmapping
Then explore the world with the teleop_twist_keyboard or with the already launched rqt_robot_steering GUI plugin:

When you finished exploring the new world, use the map_saver node from the map_server package to store the mapped enviornment:
rosrun map_server map_saver -f ~/map
RViz
View just the diffbot_description in RViz.
roslaunch diffbot_description view_diffbot.launch

Navigating and Mapping on the real Robot
The following video shows how to map a new environment and navigate in it
Start by setting up the ROS Network, by making the development PC the rosmaster (set the ROS_MASTER_URI environment variable accordingly, see ROS Network Setup for more details),
Then follow the steps listed below to run the real Diffbot or Remo robot hardware:
-
First, brinup the robot hardware including its laser with the following launch file from the diffbot_bringup package.
Make sure to run this on the real robot (e.g. connect to it via ssh):
roslaunch diffbot_bringup bringup_with_laser.launch
-
Then, in a new terminal on your remote/work development machine (not the single board computer) run the slam gmapping with the same command as in the simulation:
roslaunch diffbot_slam diffbot_slam.launch slam_method:=gmapping
As you can see in the video, this should open up RViz and the rqt_robot_steering plugin.
-
Next, steer the robot around manually either using the keyboard_teleop node or using the rqt_robot_steering node
and save the map with the following command when you are done exploring:
rosrun map_server map_saver -f office
After the mapping process it is possible to use the created map for navigation, after running the following launch files:
-
On the single board computer (e.g. Raspberry Pi) make sure that the following is launched:
roslaunch diffbot_bringup bringup_with_laser.launch
-
Then on the work/remote development machine run the diffbot_hw.lauch from the diffbot_navigation package:
roslaunch diffbot_navigation diffbot_hw.lauch
Among other essential navigation and map server nodes, this will also launch an instance of RViz on your work pc where you can use its tools to:
- Localize the robot with the “2D Pose Estimate” tool (green arrow) in RViz
- Use the “2D Nav Goal” tool in RViz (red arrow) to send goals to the robot
:construction: Future Work
Contributions to these tasks are welcome, see also the contribution section below.
ROS 2
- Migrate from ROS 1 to ROS 2
Drivers, Odometry and Hardware Interface
- Add
diffbot_driver package for ultrasonic ranger, imu and motor driver node code.
- Make use of the imu odometry data to improve the encoder odometry using a Kalman filter, such as
robot_localization (or the less active robot_pose_ekf).
- The current implementation of the ROS Control
hardware_interface::RobotHW uses a high level PID controller. This is working but also
test a low level PID on the Teensy 3.2 mcu using the Arduino library of the Grove i2c motor driver. -> This is partly implemented (see diffbot_firmware)
Also replace Wire.h with the improved i2c_t3 library.
Navigation
- Test different global and local planners and add documentation
- Add
diffbot_mbf package using move_base_flex, the improved version of move_base.
Perception
To enable object detection or semantic segmentation with the RPi Camera the Raspberry Pi 4 B will be upated with a Google Coral USB Accelerator.
Possible useful packages:

Teleoperation
Part List Diffbot
| SBC RPi 4B |
MCU Teensy 3.2 |
IMU Bosch |
 |
 |
 |
| Part |
Store |
| Raspberry Pi 4 B (4 Gb) |
Amazon.com, Amazon.de |
| SanDisk 64 GB SD Card Class 10 |
Amazon.com, Amazon.de |
| Robot Smart Chassis Kit |
Amazon.com, Amazon.de |
| SLAMTEC RPLidar A2M8 (12 m) |
Amazon.com, Amazon.de |
| Grove Ultrasonic Ranger |
Amazon.com, Amazon.de |
| Raspi Camera Module V2, 8 MP, 1080p |
Amazon.com, Amazon.de |
| Grove Motor Driver |
seeedstudio.com, Amazon.de |
| I2C Hub |
seeedstudio.com, Amazon.de |
| Teensy 4.0 or 3.2 |
PJRC Teensy 4.0, PJRC Teensy 3.2 |
| Hobby Motor with Encoder - Metal Gear (DG01D-E) |
Sparkfun |
Part List Remo
Additional (Optional) Equipment
| Part |
Store |
| PicoScope 3000 Series Oscilloscope 2CH |
Amazon.de |
| VOLTCRAFT PPS-16005 |
Amazon.de |
| 3D Printer for Remo’s parts |
Prusa, Ultimaker, etc. or use a local print service or an online one such as Sculpteo |
Hardware Architecture and Wiring
DiffBot

Remo

:handshake: Acknowledgment
:wrench: Contributing
Your contributions are most welcome. These can be in the form of raising issues, creating PRs to correct or add documentation and of course solving existing issues or adding new features.
:pencil: License
diffbot is licenses under the BSD 3-Clause.
The wheel meshes are the exception: GrabCAD’s terms apply to them, see the notice next to wheel.stl.
See also open-source-license-acknowledgements-and-third-party-copyrights.md.
The documentation is licensed differently,
visit its license text to learn more.




评论