MIT License

项目介绍

mithi/hexapod-robot-simulator 是一个托管在 GitHub 上的开源项目,主要使用 Python 编写,采用 MIT License 许可证,目前获得 888 个 Star、123 次 Fork。

仓库全名
mithi/hexapod-robot-simulator
开源许可证
MIT License
Star 数
888
Fork 数
123
未关闭 Issue
10

README 摘要

Mithi's Hexapod Robot Simulator A bare minimum browser-based hexapod robot simulator built from first principles 🕷️ If you like this project, consider buying me a few ☕ cups of coffee. 💕 Announcement You might be interested in checking out my rewrite in Javascript, live at: https://hexapod.netlify.app/ , which is like 10000000x faster. If you'd like to build you're own user interface with Node, you can download…

完整内容见 GitHub 原始 README 或本页 。

常见问题

hexapod-robot-simulator 用什么语言开发?

主要使用 Python 编写,采用 MIT License 许可证,目前有 888 个 Star。

hexapod-robot-simulator 可以免费商用吗?

仓库采用 MIT License 许可证,可免费使用与修改,商业使用请遵守许可证条款(例如保留版权声明与许可声明)。

如何获取 hexapod-robot-simulator 的源码?

可以直接克隆仓库:git clone https://github.com/mithi/hexapod-robot-simulator.git,默认分支为 master;安装与运行步骤见仓库 README。

hexapod-robot-simulator 最近还在维护吗?

仓库最近一次更新为 1月1日,当前有 10 个未关闭 Issue;Star 数为 888,可作为社区活跃度的参考。

关于

GitHub 原始描述(英文)

A hexapod robot simulator built from first principles

描述取自 GitHub 官方 API,保持仓库作者书写的原文。

语言占比

CSS
Procfile
Python
Shell

Release

README

codecov Code Climate License: MIT Code style: black PRs welcome! first-timers-only

Mithi’s Hexapod Robot Simulator

Twisting turning and tilting Adjusting camera view

Announcement

You might be interested in checking out my rewrite in Javascript, live at: https://hexapod.netlify.app/ , which is like 10000000x faster. If you’d like to build you’re own user interface with Node, you can download the algorithm alone as a package in the npm registry: Hexapod Kinematics Library. There is also a “fork” modified where you can use the app to control a physical hexapod robot as you can see in the gif below.

drawing

Features

STATUS FEATURE DESCRIPTION
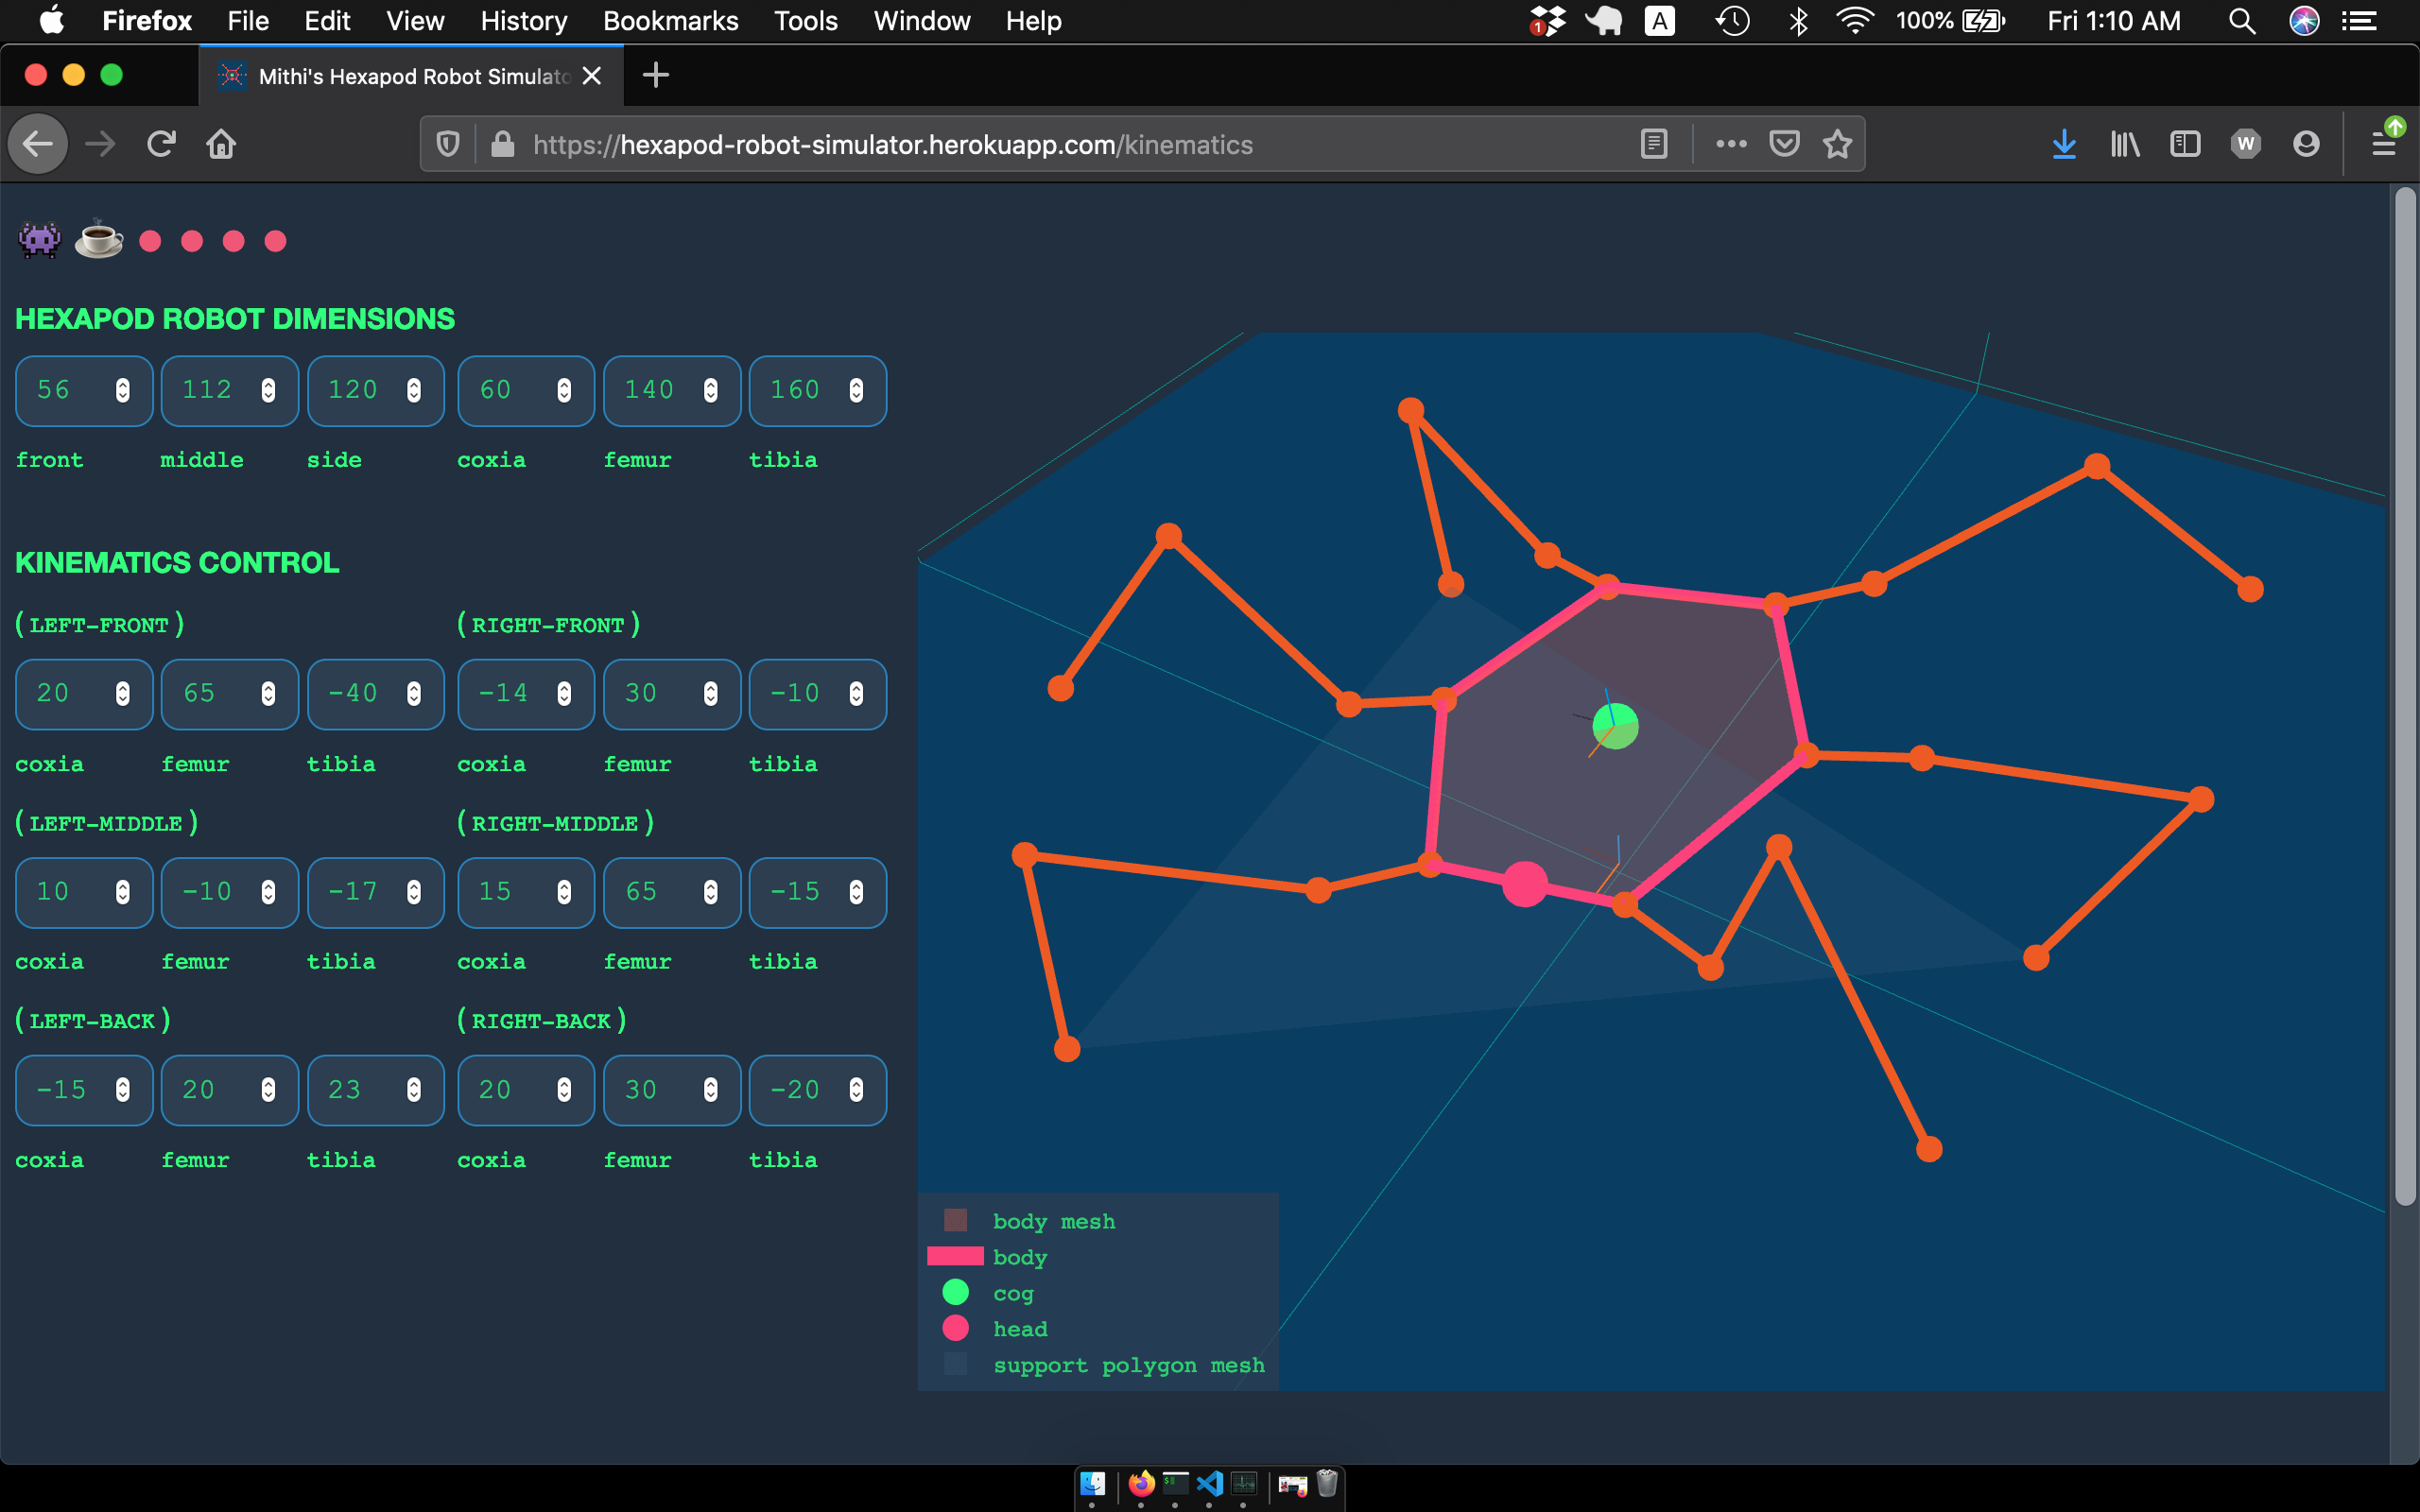
🎉 Forward Kinematics Given the angles of each joint, what does the robot look like?
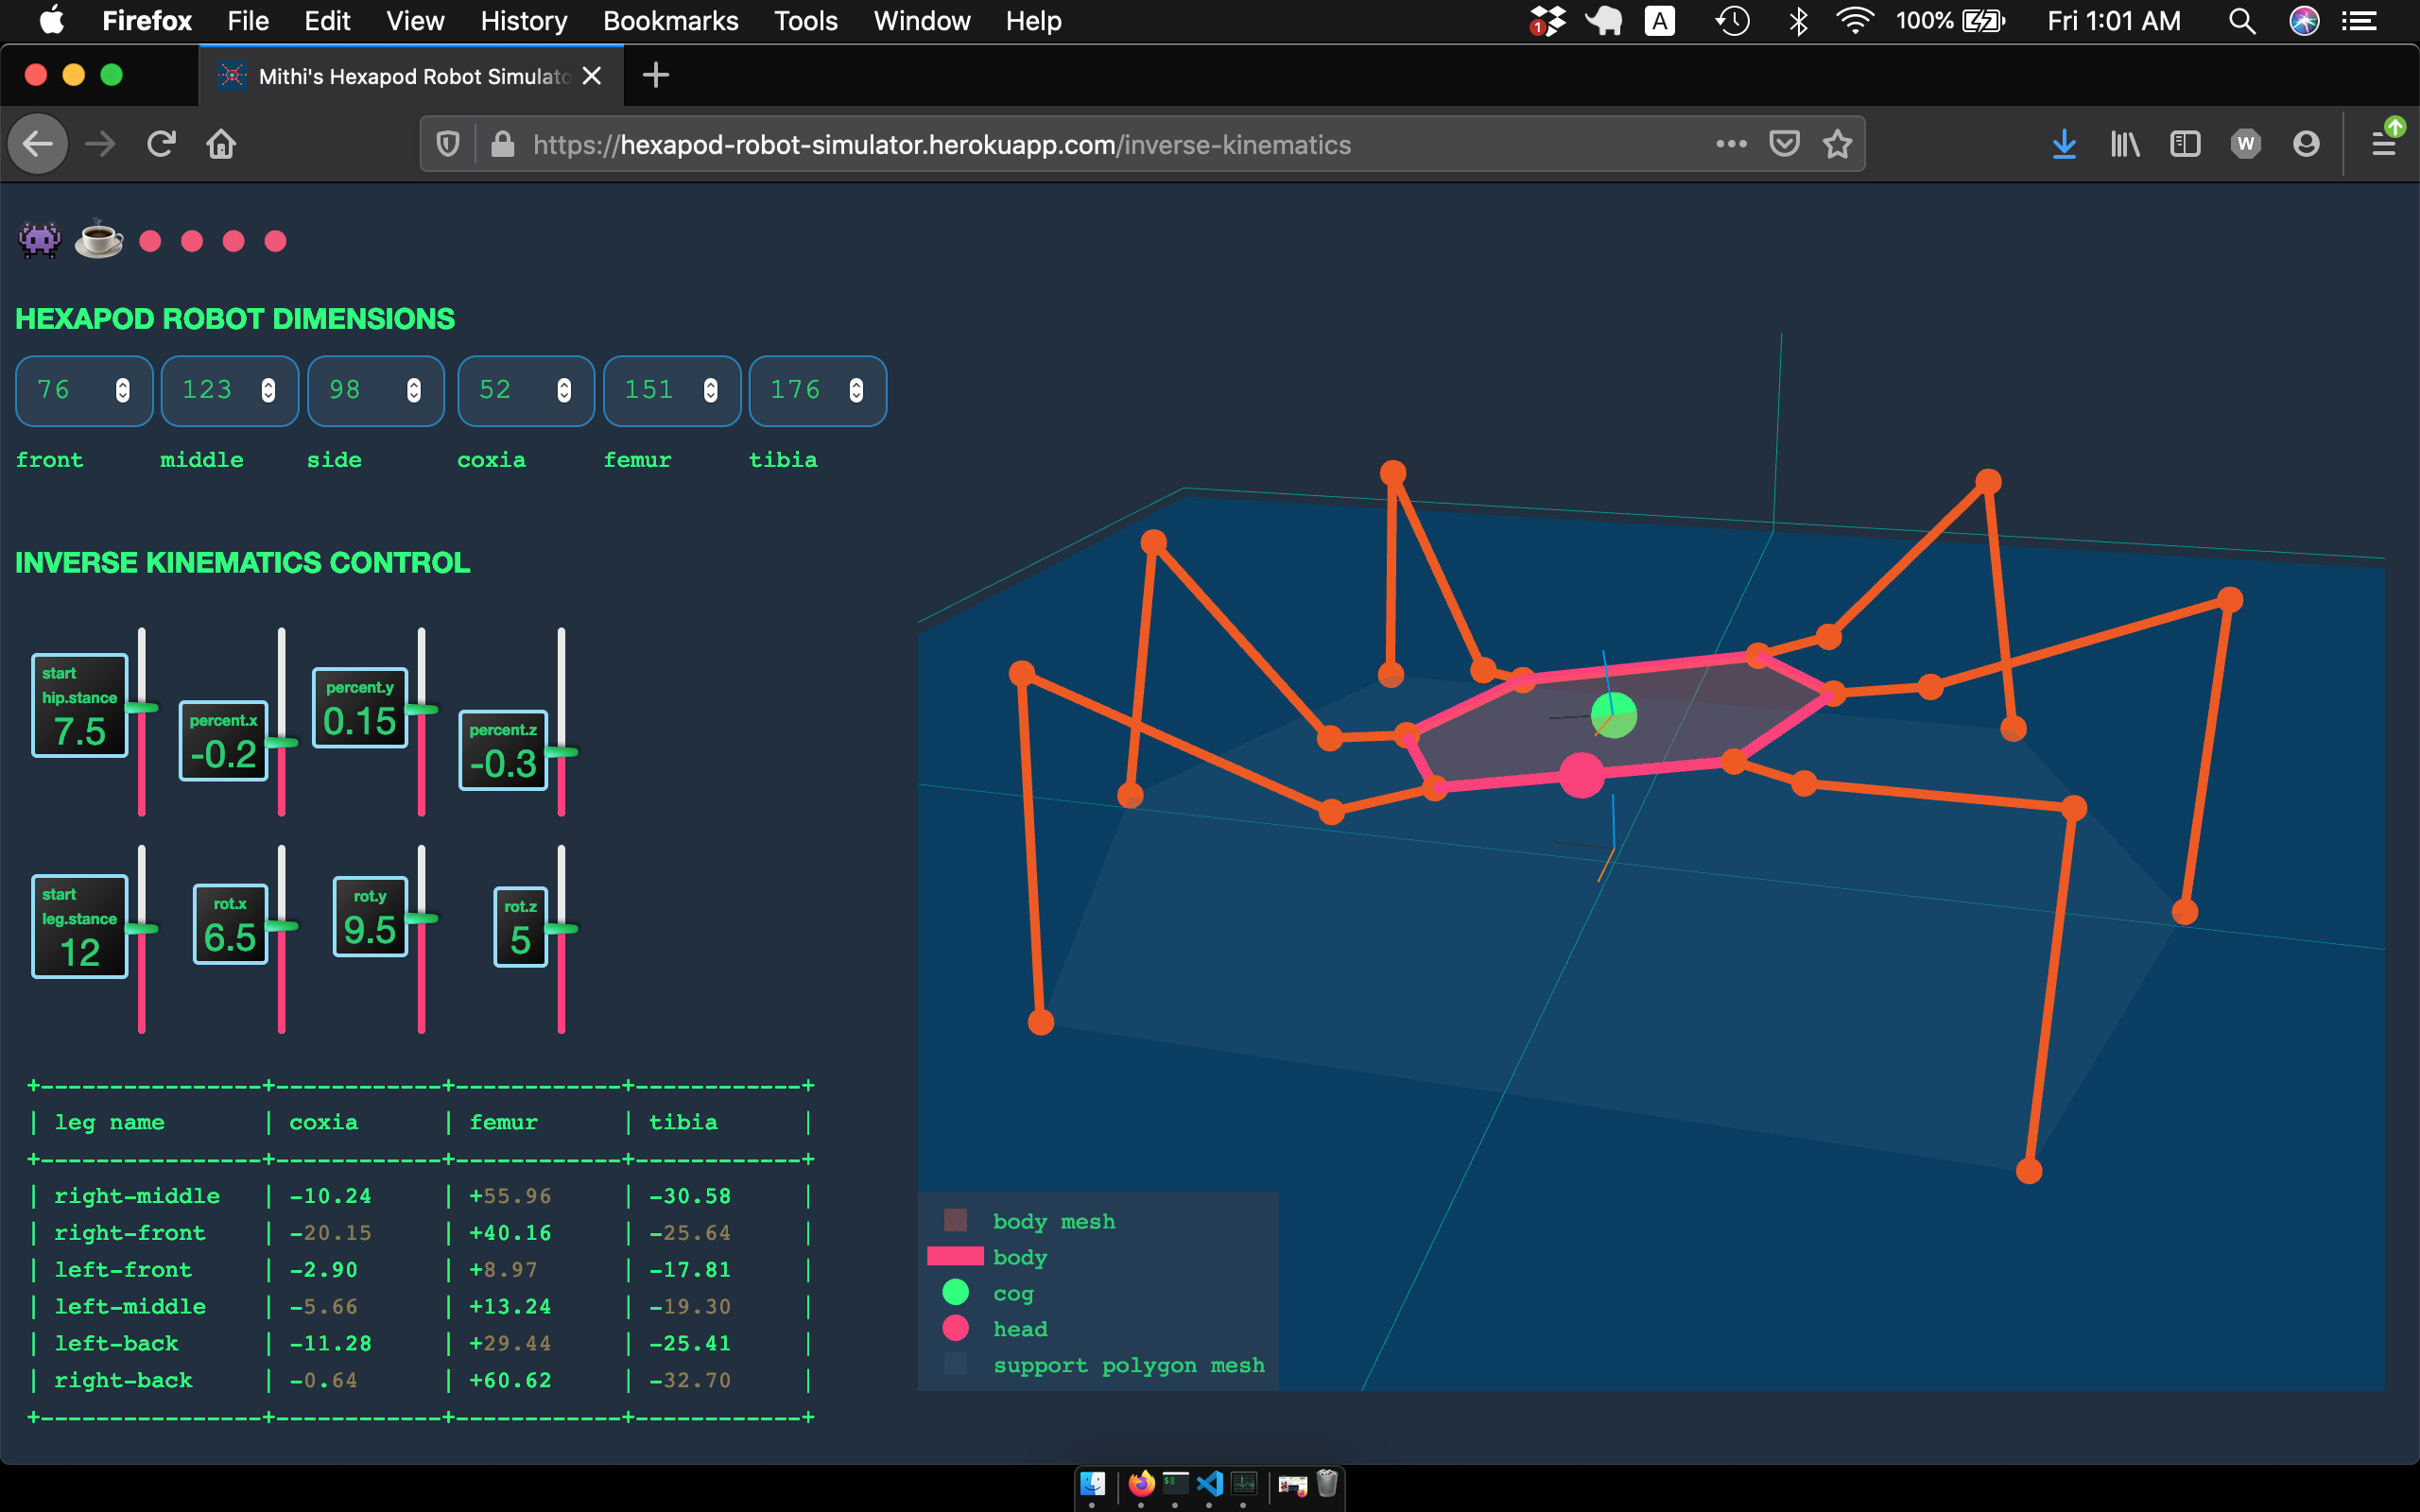
🎉 Inverse Kinematics What are the angles of each joint to make the robot look the way I want? Is it even possible? Why or why not?
🎉 Uniform Movements If all of the legs behaved the same way, how will the hexapod robot as a whole behave?
🎉 Customizability Set the dimensions and shape of the robot’s body and legs. (6 parameters)
🎉 Usability Control the camera view, pan, tilt, zoom, whatever.
🎉 Simplicity Minimal dependencies. Depends solely on Numpy for calculations. Uses only Plotly Dash for plotting, Dash can be safely replaced if a better 3d plotting library is available.
❗ Stability Check (WIP) If we pose the robot in a particular way, will it fall over?
❗ Fast Okay, it’s not as fast as I wanted, but when run locally, it’s okay
❗ Bug-free Fine, right now there’s still room for improvement
❗ Well-tested Yeah, I need to compile test cases first

Preview

image image
image image

Requirements

  • Python 3.8.1
  • Plotly Dash 1.18.1
  • Plotly Dash Daq 0.5.0
  • Numpy 1.19.5
  • See also ./requirements.txt

Run

$ python index.py
Running on http://127.0.0.1:8050/

Screenshots

Kinematics
IK

More Information

Check the Wiki for more additional information

🤗 Contributors

评论

暂无评论