End-to-end Autonomous Driving
This repo is all you need for end-to-end autonomous driving research. We present awesome talks, comprehensive paper collections, benchmarks, and challenges.
Table of Contents
At a Glance
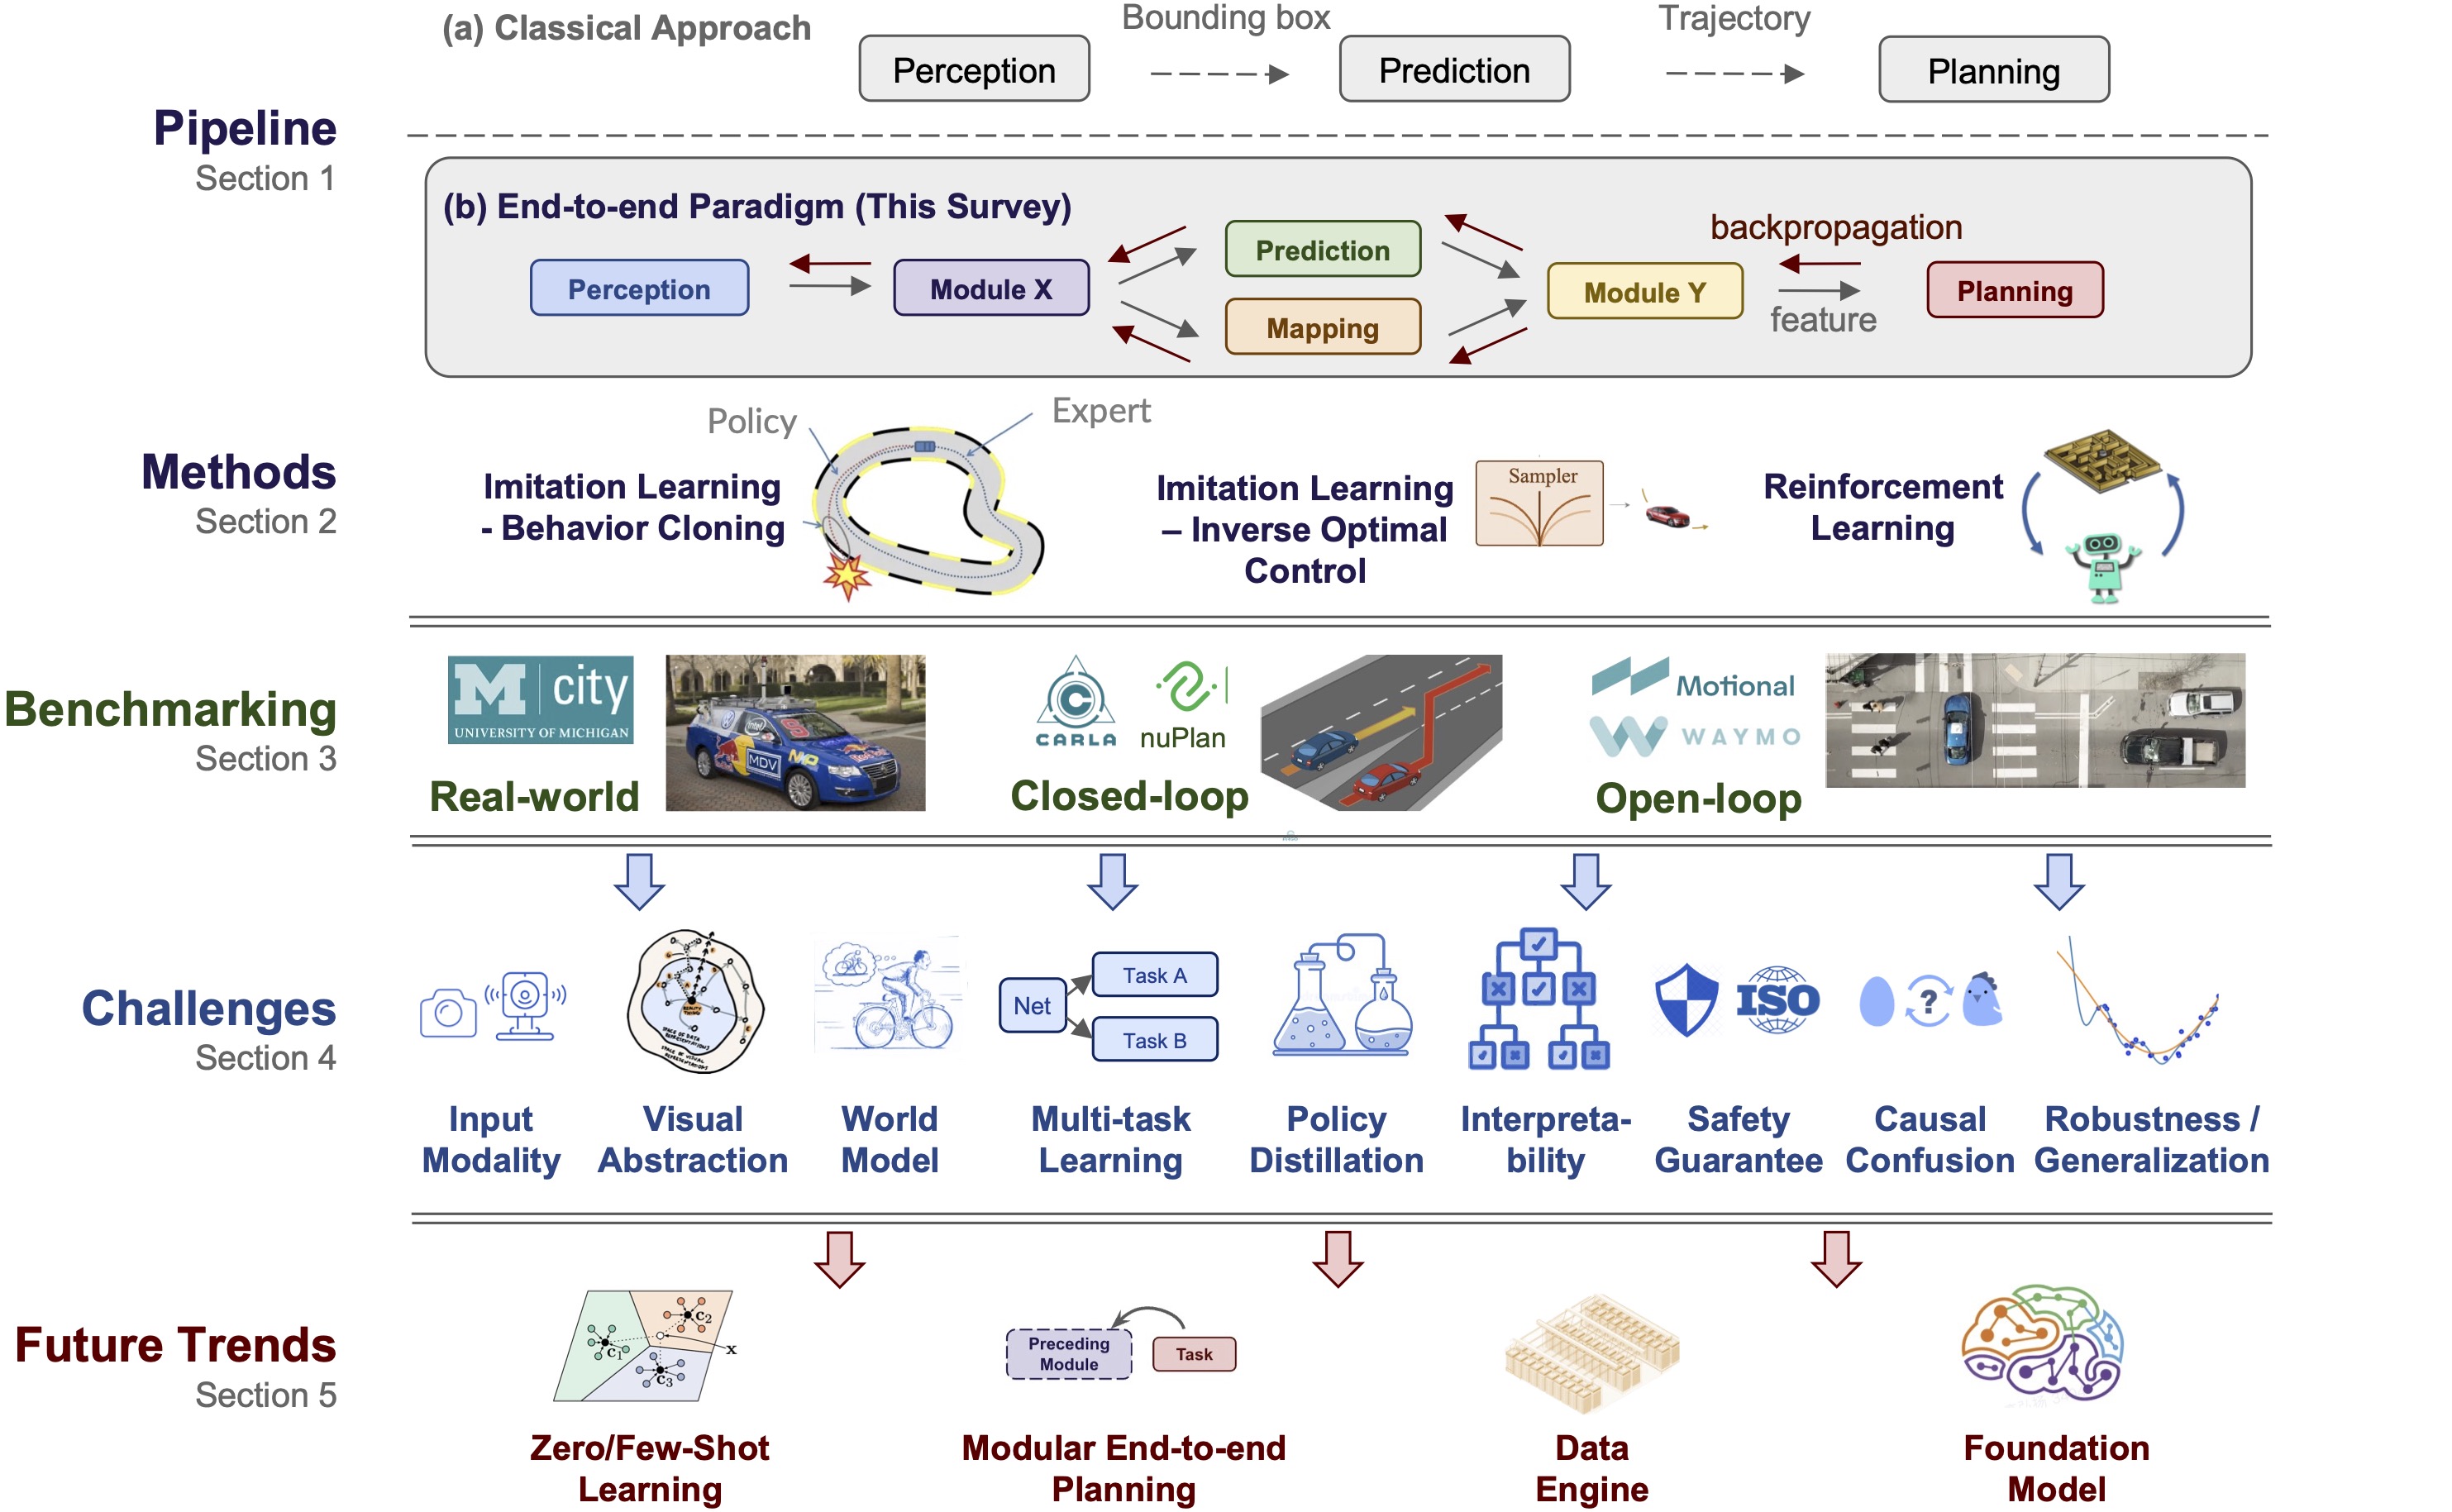
The autonomous driving community has witnessed a rapid growth in approaches that embrace an end-to-end algorithm framework, utilizing raw sensor input to generate vehicle motion plans, instead of concentrating on individual tasks such as detection and motion prediction. In this survey, we provide a comprehensive analysis of more than 270 papers on the motivation, roadmap, methodology, challenges, and future trends in end-to-end autonomous driving. More details can be found in our survey paper.
End-to-end Autonomous Driving: Challenges and Frontiers
Li Chen1,2, Penghao Wu1, Kashyap Chitta3,4, Bernhard Jaeger3,4, Andreas Geiger3,4, and Hongyang Li1,2
1 OpenDriveLab, Shanghai AI Lab, 2 University of Hong Kong, 3 University of Tübingen, 4 Tübingen AI Center
If you find some useful related materials, shoot us an email or simply open a PR!
(back to top)
Learning Materials for Beginners
Online Courses
(back to top)
Workshops and Talks
Workshops (recent years)
Workshops (previous years)
Talks
Relevant talks from other workshops
(back to top)
Paper Collection
We list key challenges from a wide span of candidate concerns, as well as trending methodologies. Please refer to this page for the full list, and the survey paper for detailed discussions.
(back to top)
Benchmarks and Datasets
Real-world deployment is the final benchmark for autonomous driving.
However, testing in the real world is expensive. For academic benchmarking, we recommend you read this write-up from Jaeger et al. 2024: Common mistakes in benchmarking.
Closed-loop
Open-loop
(back to top)
Competitions / Challenges
- End-to-End Driving at Scale, Foundation Models for Autonomous Systems, CVPR 2024
- CARLA Autonomous Driving Challenge, Foundation Models for Autonomous Systems, CVPR 2024
- nuPlan planning, Workshop on End-to-end Autonomous Driving, CVPR 2023
- CARLA Autonomous Driving Challenge 2022, Machine Learning for Autonomous Driving, NeurIPS 2022
- CARLA Autonomous Driving Challenge 2021, Machine Learning for Autonomous Driving, NeurIPS 2021
- CARLA Autonomous Driving Challenge 2020, Machine Learning for Autonomous Driving, NeurIPS 2020
- Learn-to-Race Autonomous Racing Virtual Challenge, 2022
- INDY Autonomous Challenge
(back to top)
Contributing
Thank you for all your contributions. Please make sure to read the contributing guide before you make a pull request.
(back to top)
License
End-to-end Autonomous Driving is released under the MIT license.
(back to top)
Citation
If you find this project useful in your research, please consider citing:
@article{chen2023e2esurvey,
  title={End-to-end Autonomous Driving: Challenges and Frontiers},
  author={Chen, Li and Wu, Penghao and Chitta, Kashyap and Jaeger, Bernhard and Geiger, Andreas and Li, Hongyang},
  journal={IEEE Transactions on Pattern Analysis and Machine Intelligence},
  year={2024}
}
(back to top)
Primary contact: [email protected]. You can also contact: [email protected].
Join OpenDriveLab Slack to chat with the commuty! Slack channel: #e2ead.
(back to top)


评论